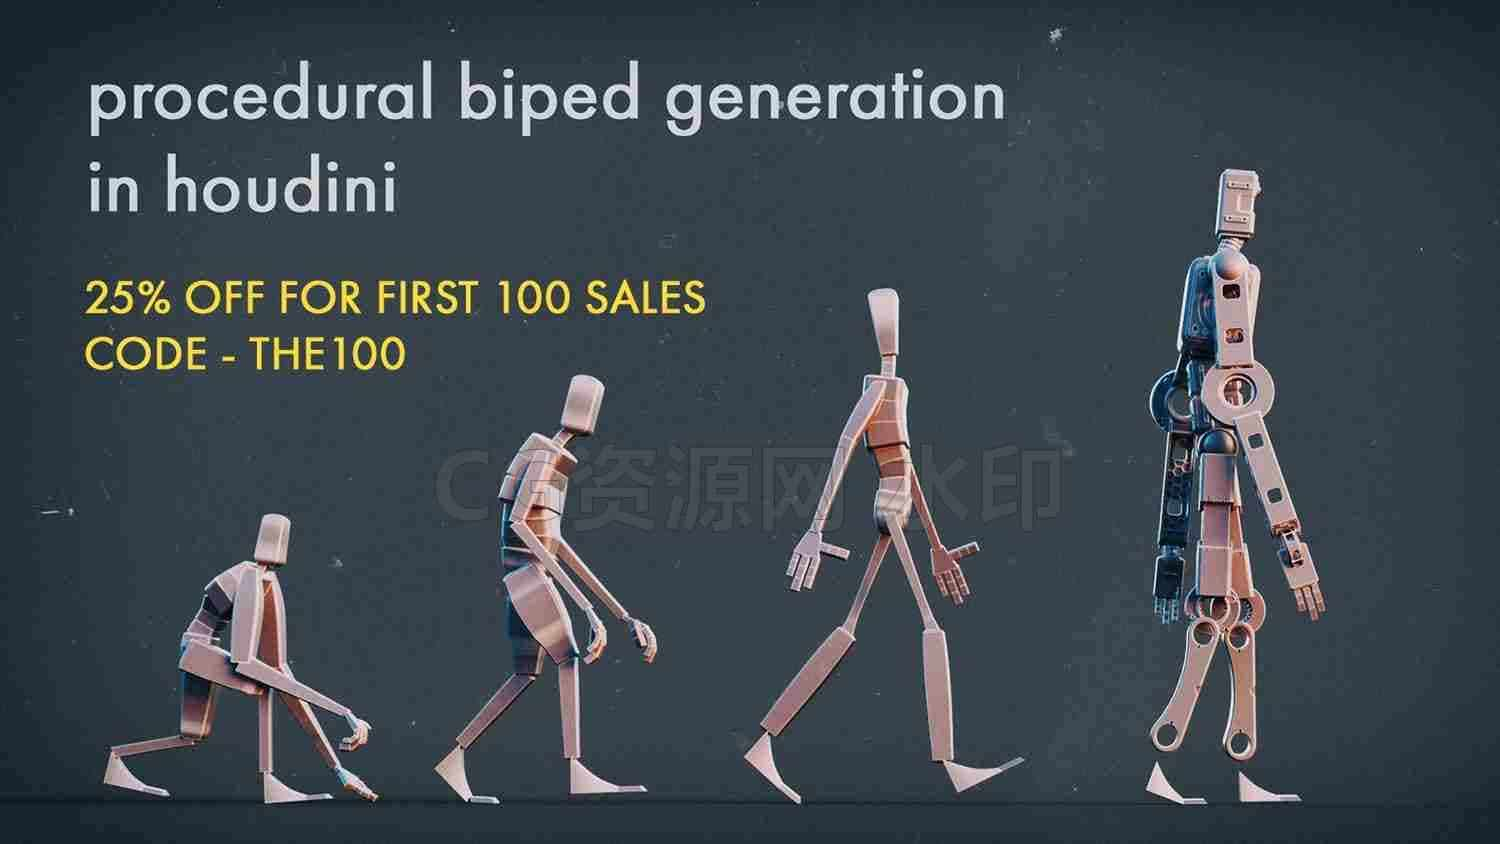
Content Details – 9 Video Chapters (with Audio)
lesson plan
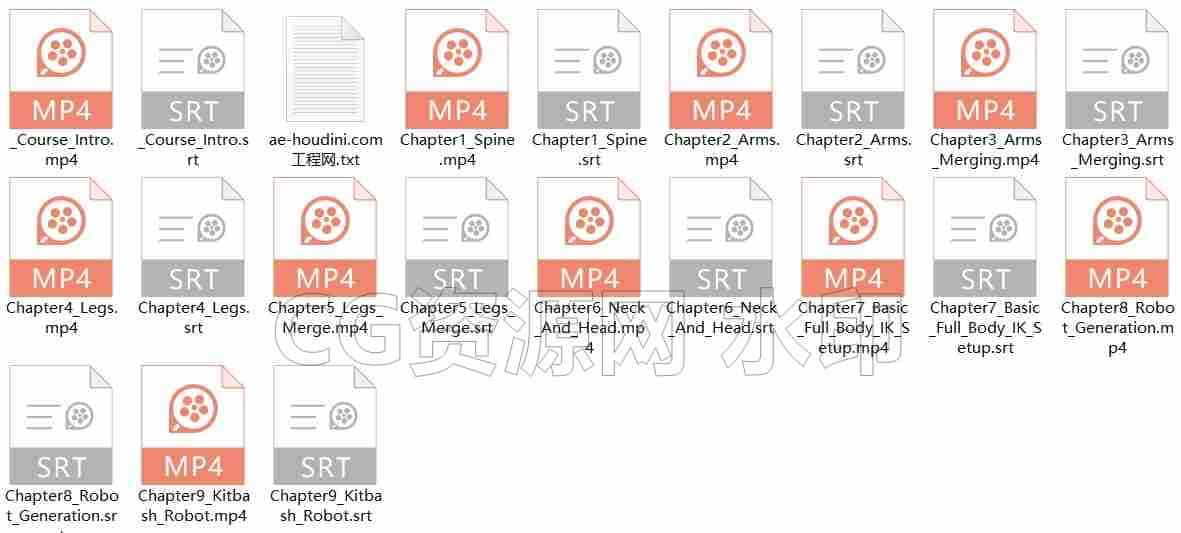
- Spine – Starting the biped with the spine construction and setting controls to adjust the shape of the torso geometry
- Arms – creating the arms rig and geometry
- Arms merge – combining the arms rig with the spine
- Legs – making the legs
- Legs merge – combining the legs with he existing rig
- Neck and Head – completing the biped by making the head and the neck
- Basic Full body IK – Setting up basic full body IK to pose the Biped
- Robot – Putting the biped system to proper use and building a full robot
- Kit bash Robot – Creating a procedural robot by replacing parts of the biped with items from a kit bash library.
- 内容详细信息-9个视频章节(带音频)
- 课程计划
- 脊椎-使用脊椎构造和设置控件启动两足动物以调整躯干几何体的形状
- 手臂-创建手臂装备和几何体
- 手臂合并-将手臂装备与脊椎结合
- 腿部-制作腿部
- 腿部合并-将腿部与现有装备相结合
- 颈部和头部-通过制作头部和颈部来完成两足动物
- 基本全身IK-设置基本全身IK以设置Biped的姿势
- 机器人-正确使用两足动物系统并构建完整的机器人
- Kit bash Robot-通过用Kit bash库中的项目替换两足动物的部分来创建程序机器人。
-
-
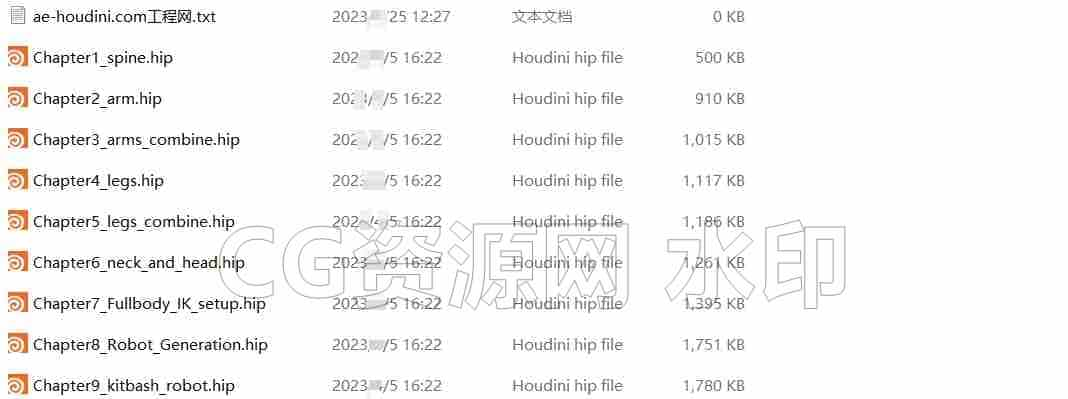
注释 10个视频 带工程
THE END